Sep 3, 2026
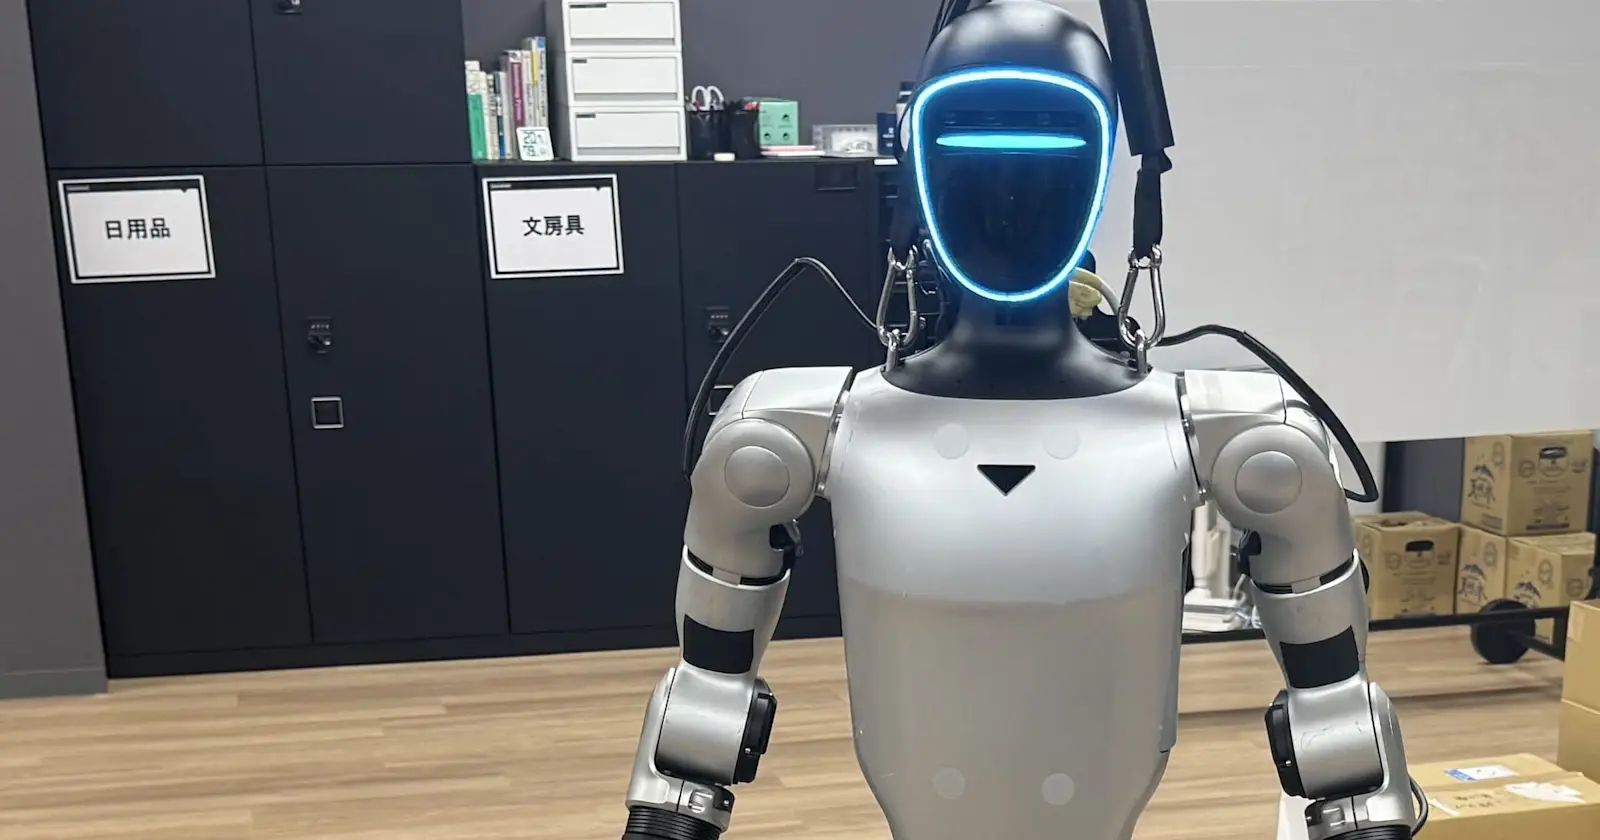
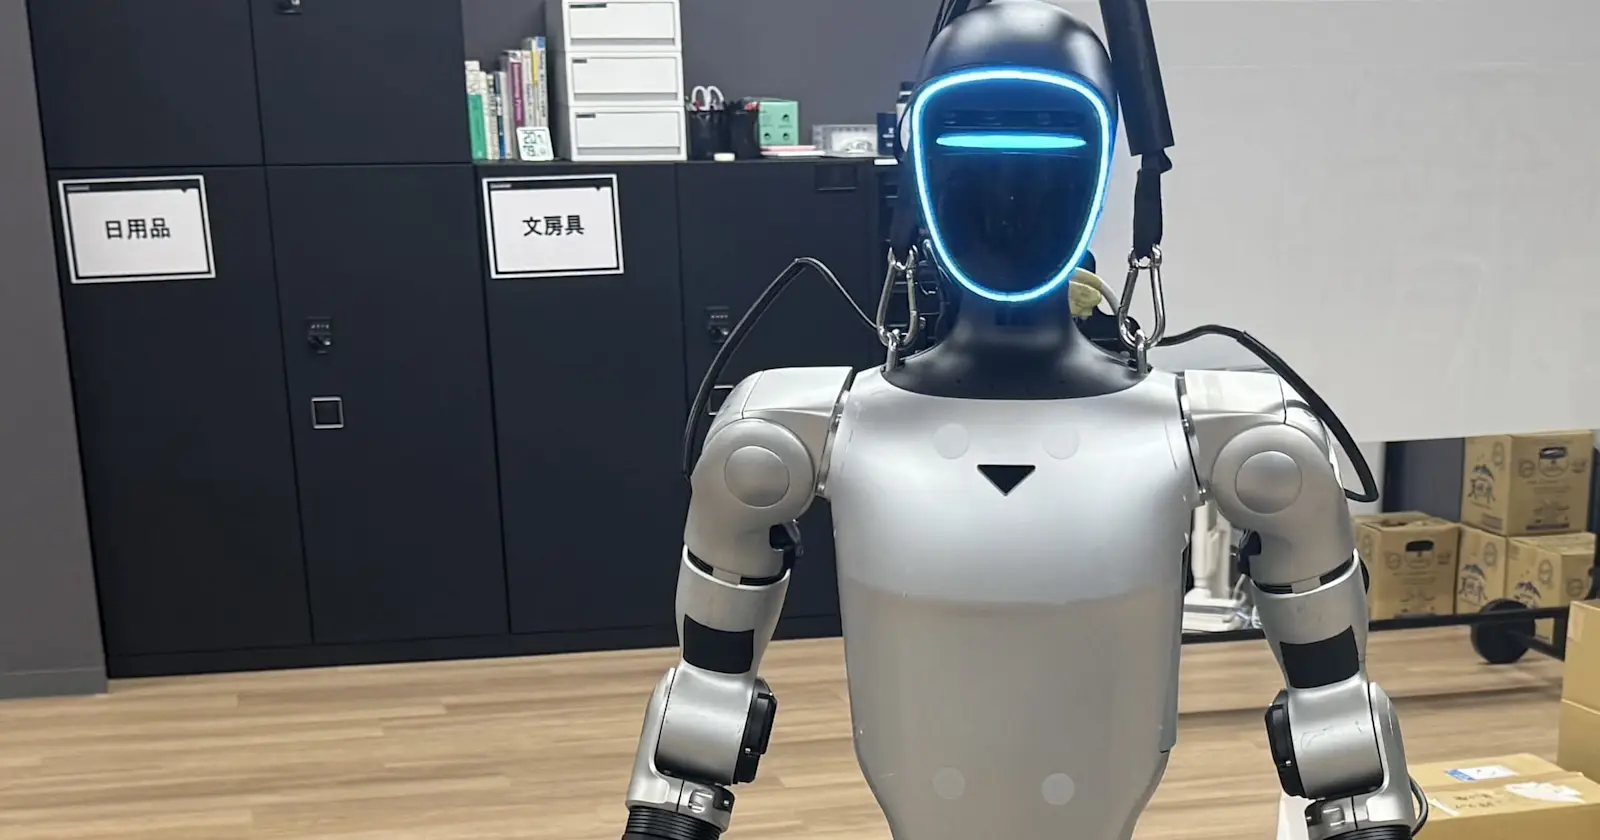
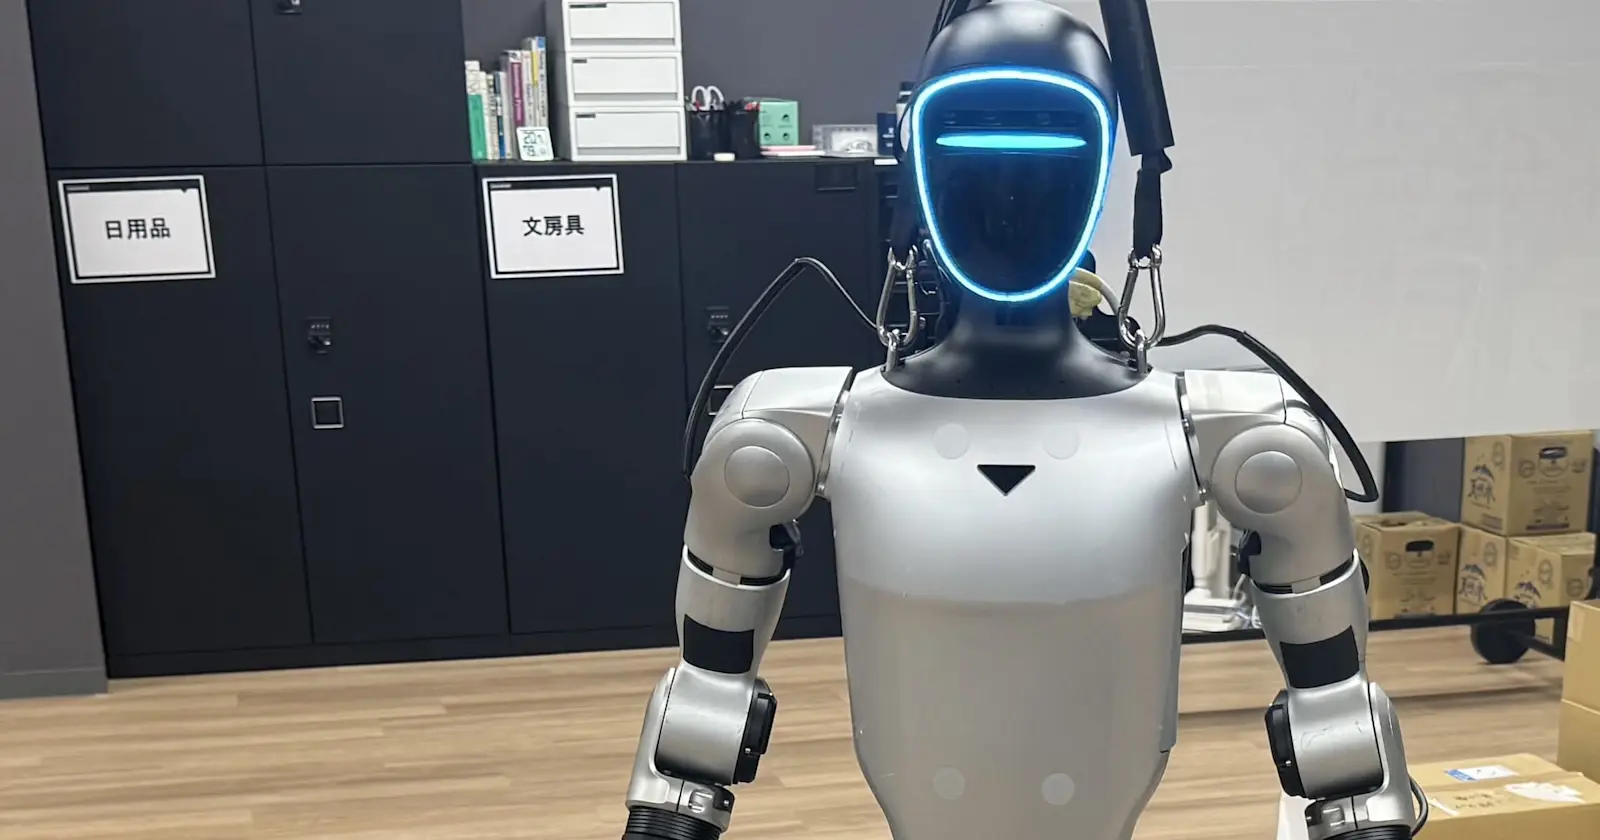
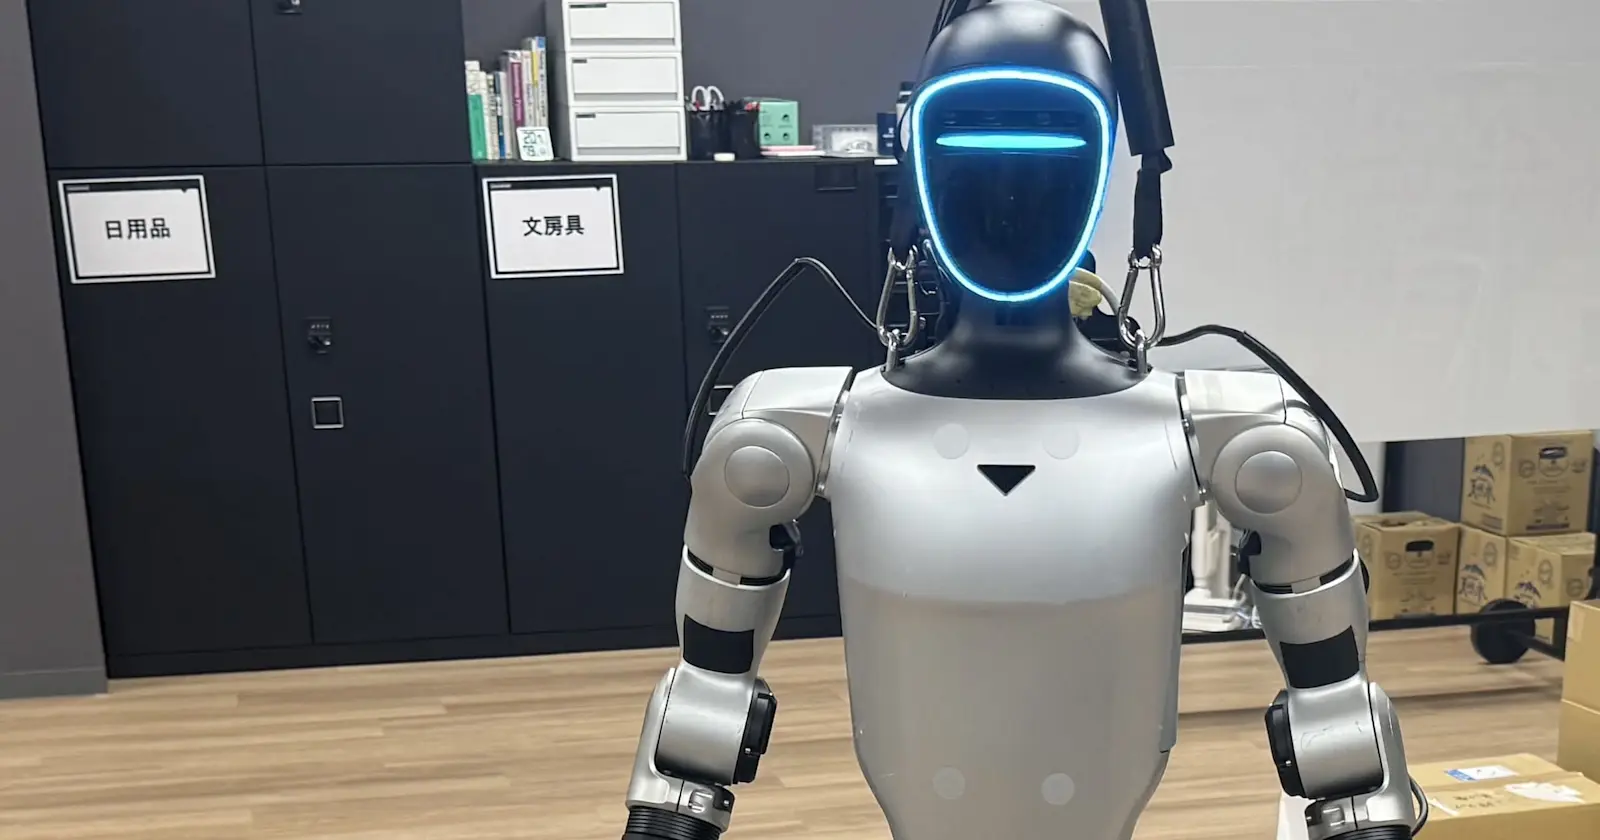
G1 Bottle Pick-and-Lift: Sim-to-Real Grasping and Lifting with a 600 ml Bottle
Final report: transferring the hybrid Isaac Lab and PPO system to a real Unitree G1 for bottle grasping and lifting.
Writing
A lightweight space for technical notes, personal reflections, travel logs, and the small transitions between places.

Sep 3, 2026
Final report: transferring the hybrid Isaac Lab and PPO system to a real Unitree G1 for bottle grasping and lifting.

Aug 20, 2026
Week 3: improving integrated success with object-relative control and moving the learned policy toward real G1 deployment.

Aug 14, 2026
Week 2: scaling to a 0.62 kg bottle while developing curriculum learning and a safer approach policy.

Aug 5, 2026
Week 1: building the first reinforcement-learning MVP for bottle grasping and lifting with Unitree G1.

Jul 30, 2026
Final report: optimizing the inspection pipeline and completing the PoC with Go2 and G1 camera compatibility.

Jul 23, 2026
Week 3: replacing unstable VLM reasoning with grounded detection and deterministic geometric risk policies.

Jul 16, 2026
Week 2: connecting the Go2 camera to a persistent local VLM pipeline for continuous visual inspection.

Jul 9, 2026
Week 1: designing and implementing the first end-to-end MVP for a robot visual inspection agent.
Jun 1, 2026
The first post, but no technical content, just a reflection.